190 lesson: ask the wheels for a speed
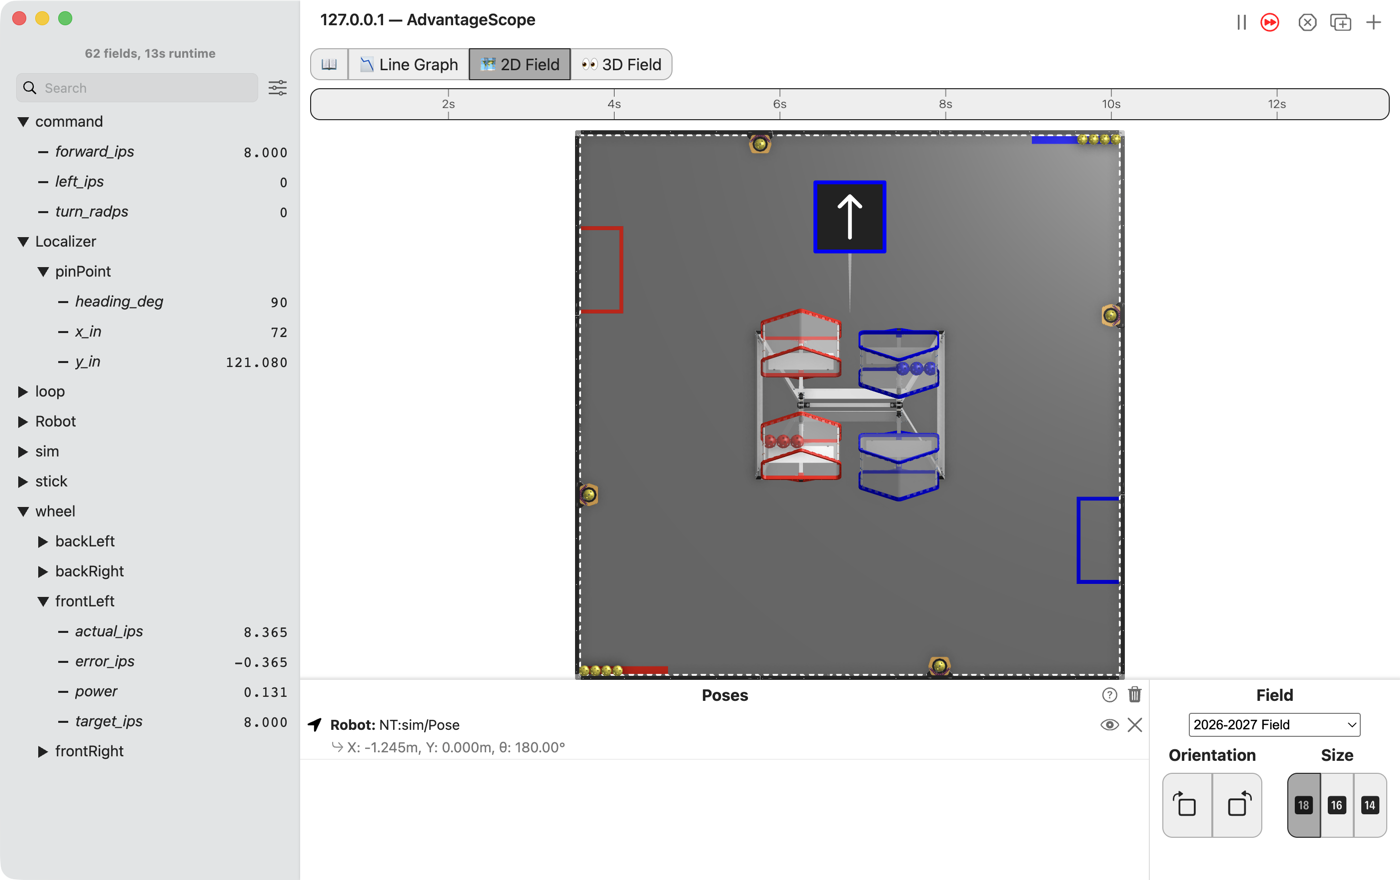
Full stick means 40 inches per second, not full power. The drivetrain measures how fast each wheel turns and makes up the difference, on a fresh battery or a flat one, on the flat or up a slope.
the steps
L190S010: copy the two starters into mytry
This lesson has two files, as L110 did. One is the OpMode. The other is the drivetrain, which turns a speed into a power.
Copy. In lessons, click L190SpeedDriveTrain once and copy it. Click mytry once and
paste. In the Copy Class box, click OK. If Android Studio asks whether to add the file to
Git, click Add. Do the same for L190VelocityDriveOpMode.
Check.
mytryholdsL190SpeedDriveTrainandL190VelocityDriveOpMode.
L190S020: switch your copy on
Change. In L190VelocityDriveOpMode, delete the line @Disabled, under the comment that names
this step.
Check.
Under the step’s comment, the next line reads
// 'public' so the robot can run this OpMode. 'public' allows access from any code.
L190S030: make room for the drivetrain
Change. Near the top of the class, find the comment that names this step. Under it, type:
    // When on L190S030, see
    // https://msb-stitt.github.io/ftc31459-26-27-biobuzz/guide/tasks/l190.html#l190s030
    // for what to do here.
    L190SpeedDriveTrain drivetrain;
Check.
The line has no red underline.
L190SpeedDriveTrainis inmytrytoo, so it needs no import.
L190S040: hand the drivetrain to the follower
Change. In init(), find the comment that names this step. Under it, type the first line
below. Then change initAfter(); to initAfter(drivetrain);:
        // When on L190S040, see
        // https://msb-stitt.github.io/ftc31459-26-27-biobuzz/guide/tasks/l190.html#l190s040
        // for what to do here.
        drivetrain = new L190SpeedDriveTrain(hardware);

        initAfter(drivetrain);
This is L110S050 again, with the new drivetrain.
Check.
Neither line has a red underline.
L190S050: turn the sticks into speeds
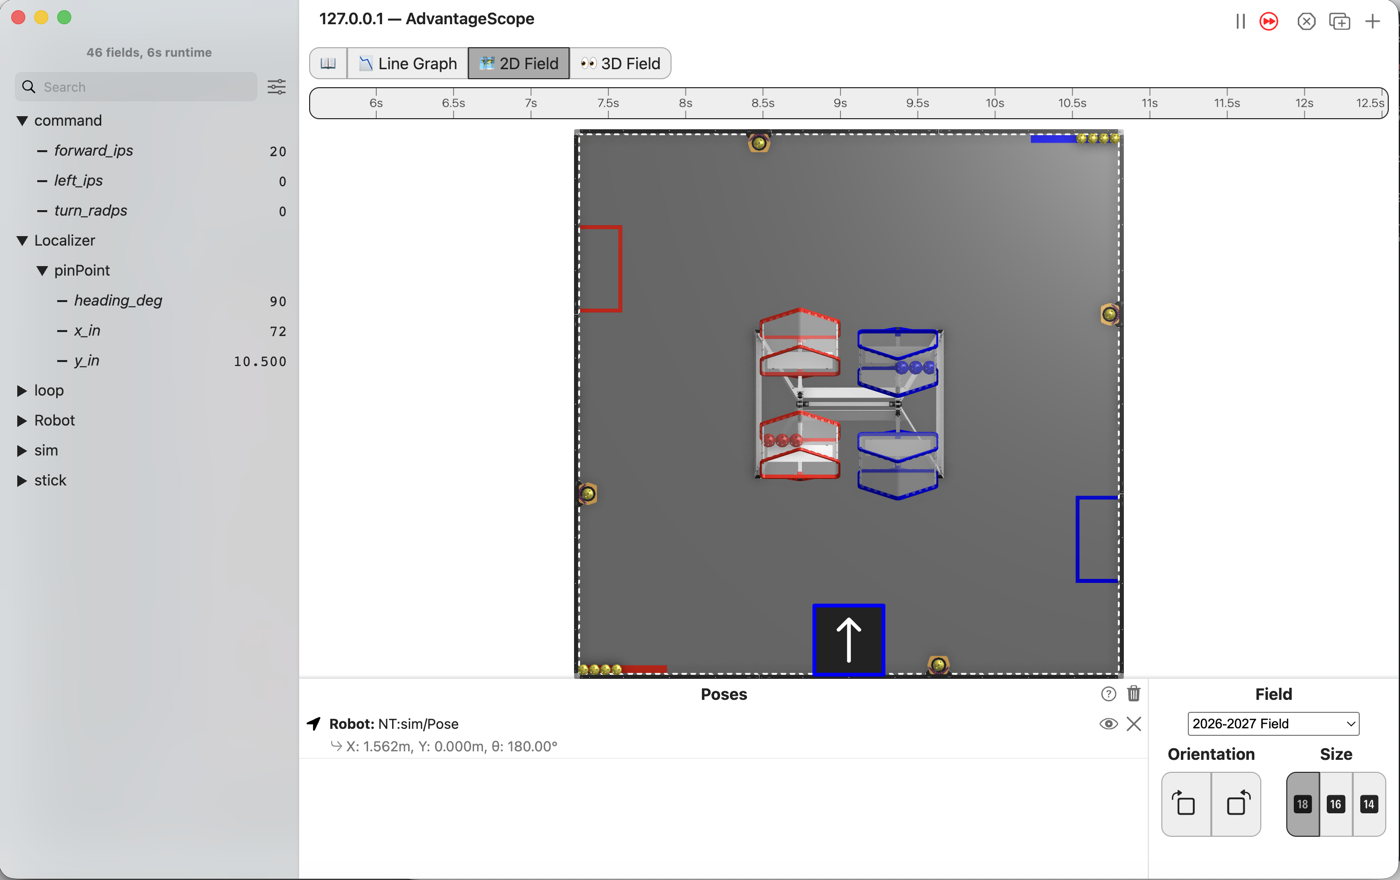
MAX_IPS is 40, in inches per second. MAX_TURN_RADPS is pi radians per second, half a turn each
second. Both are near the top of the class.
Change. In driveFromTheSticks(), find the comment that names this step. Under it are three
lines that end in = 0;. Change each 0 as below. Then, under the three publish lines, type the
last two lines:
        // When on L190S050, see
        // https://msb-stitt.github.io/ftc31459-26-27-biobuzz/guide/tasks/l190.html#l190s050
        // for what to do here.
        double forwardInPerS = deadband(-leftStickY, band) * MAX_IPS;
        double strafeInPerS = deadband(-leftStickX, band) * MAX_IPS;
        double turnRadPerS = deadband(-rightStickX, band) * MAX_TURN_RADPS;
        Tracker.publish("command/forward_ips", forwardInPerS);
        Tracker.publish("command/left_ips", strafeInPerS);
        Tracker.publish("command/turn_radps", turnRadPerS);
        double[] target = WheelTargets.forMecanum(forwardInPerS, strafeInPerS, turnRadPerS, Constants.turnRadiusInches);
        drivetrain.setCommandedWheelSpeeds(target[0], target[1], target[2], target[3]);
The minus signs are the ones from L030. A stick pushed up reads less than 0.0.
WheelTargets.forMecanum works out how fast each wheel has to turn for the robot to move like
that. It hands back an array, front left first, then front right, back left and back right.
turnRadiusInches is how far each wheel sits from the middle of the robot.
WheelTargets and Constants turn red. Hold the mouse over each one until a box offers Import
class, and click it. The box for Constants names
org.firstinspires.ftc.teamcode.pedro.Constants.
Simulator. In the Terminal, run:
./gradlew :TeamCode:simRun --args="mytry.L190VelocityDriveOpMode --left_stick_y=-0.5"
AdvantageScope. Connect to the simulator as in L020, click 2D Field, and open the command
folder. Then open Localizer and pinPoint.
Check.
forward_ipsreads 20, half of 40.The robot does not move, and
y_instays at 10.5.
The OpMode asks for a speed, but setCommandedWheelSpeeds in your drivetrain is still empty.
L190S060: turn a speed into a power
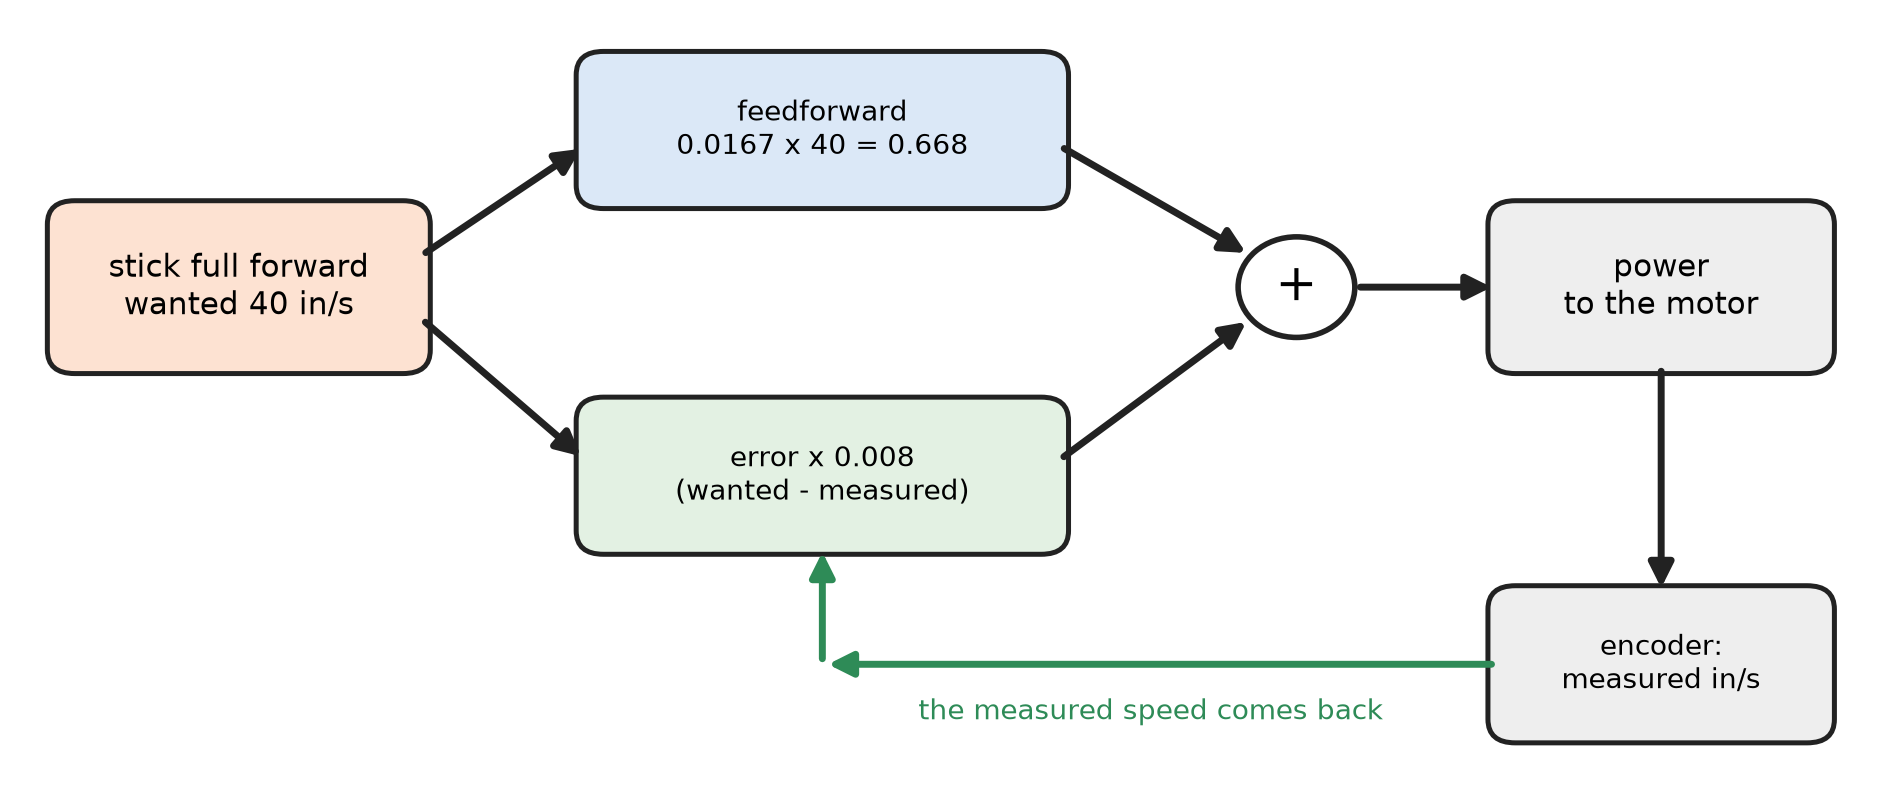
Open L190SpeedDriveTrain. It extends CorbelsMecanum, so it has everything L180’s drivetrain
had. setCommandedWheelSpeeds puts the four speeds into the array wanted. Each wheel gets its
power from two parts added together.
Feedforward is a guess, made before anything is measured.
Constants.powerPerInchPerSecondis the power one inch per second needs, so the guess gets most of the way there at once.Feedback is the correction.
measuredSpeeds.all()reads how fast each wheel really turns. The difference between wanted and measured, timesVELOCITY_KP, is added on.
The guess is always a little off, and the correction only grows once the wheel is off its speed. Together they get there and stay there.
A for loop runs the lines inside its braces once for each wheel. i starts at 0 and goes up by
1 each time, while it is less than 4. So wanted[i] is wanted[FL] the first time around, then
FR, BL and BR.
Change. Press Ctrl+C in the Terminal to stop the simulator. In setCommandedWheelSpeeds, find
the comment that names this step. Under it, type:
        // When on L190S060, see
        // https://msb-stitt.github.io/ftc31459-26-27-biobuzz/guide/tasks/l190.html#l190s060
        // for what to do here.
        double[] measured = measuredSpeeds.all();
        double[] powers = new double[4];
        for (int i = 0; i < 4; i++) {
            double feedforward = Constants.powerPerInchPerSecond * wanted[i];
            double feedback = VELOCITY_KP * (wanted[i] - measured[i]);
            powers[i] = clampToPower(feedforward + feedback);
        }
        setCommandedWheels(powers[FL], powers[FR], powers[BL], powers[BR]);
        publishWheelSpeeds(wanted, measured);
Android Studio types the } of the for loop for you, when you press Enter after the {.
clampToPower keeps each power between -1.0 and +1.0. setCommandedWheels sends the four powers to
the wheels, as in L110. publishWheelSpeeds puts each wheel’s numbers in the wheel folder.
Constants turns red. Import it as in L190S050.
Simulator. Run the command again, with the stick pushed less so the robot stays on the field longer:
./gradlew :TeamCode:simRun --args="mytry.L190VelocityDriveOpMode --left_stick_y=-0.2"
AdvantageScope. Connect, and open wheel, then frontLeft.
Check.
forward_ipsandtarget_ipsread 8.The robot drives up the field.
On the first loop
powerreads 0.198: the guess, 0.134, plus the correction for a wheel not yet turning.
actual_ips climbs to about 8 in under half a second and settles a little above 8, so error_ips
settles a little below 0.0. power drops to about 0.13 and stays there. The guess was a little too
much for the simulated robot, and the correction takes off what it needs.
L190S070: drive it up something
Robot. Stop the simulator. Send the code, run L190 Velocity Drive from the Driver Station,
and watch it in AdvantageScope.
Check.
Drive on the flat first.
Then drive straight up the mat, with the stick held in the same place. The robot slows a little at the foot of the slope and then picks back up.
In AdvantageScope,
actual_ipsdips belowtarget_ips, then climbs back, andpowerrises to do it.